Projects
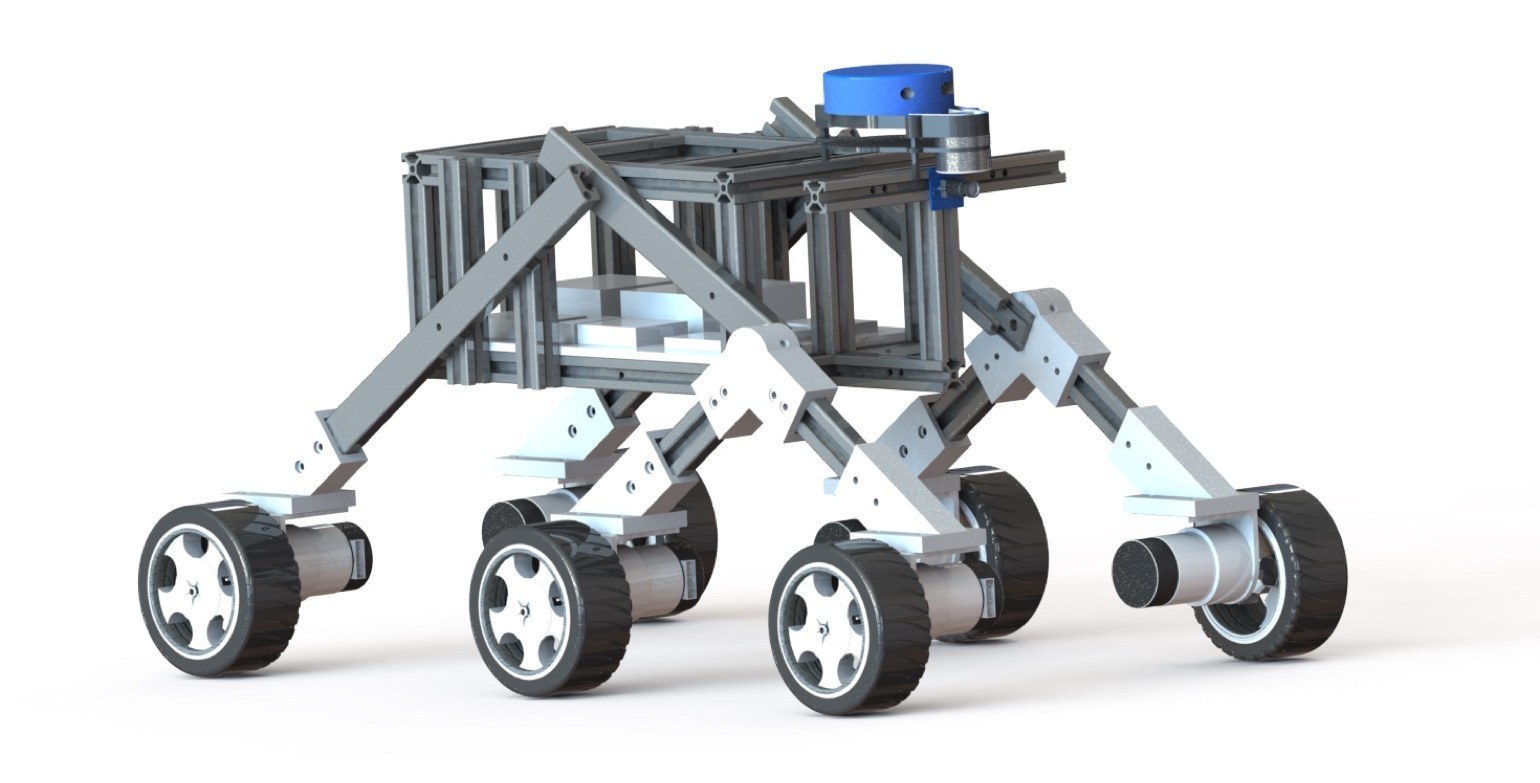
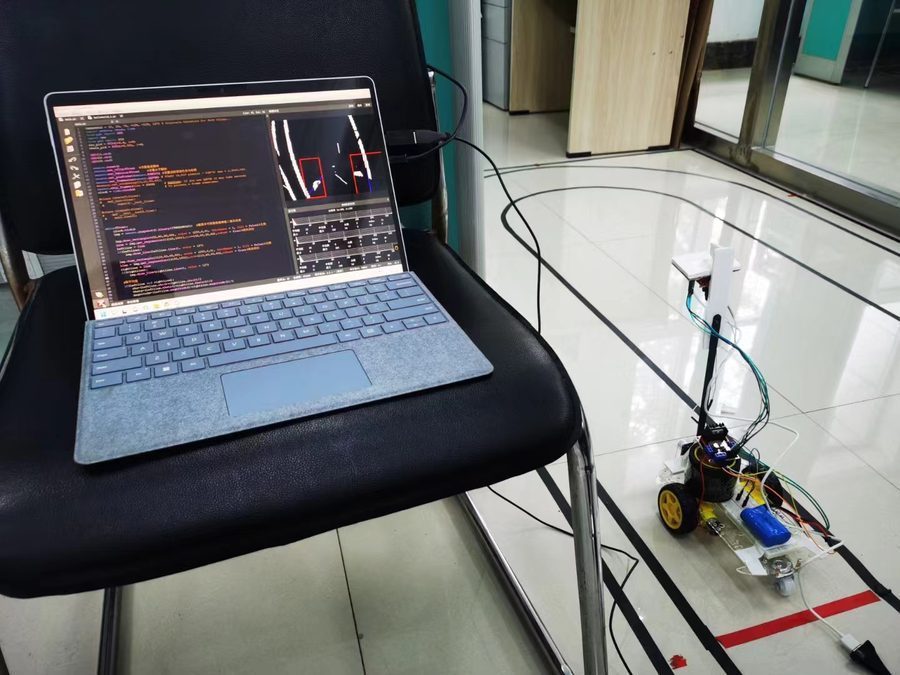
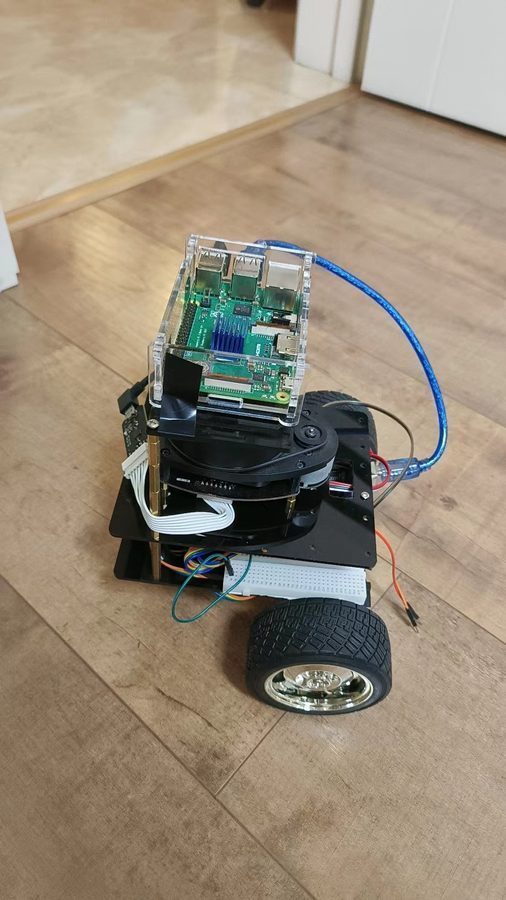
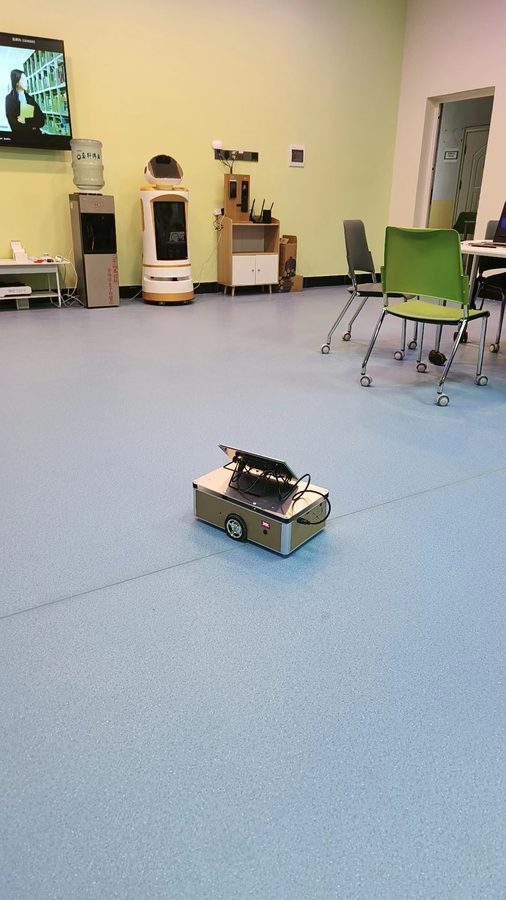
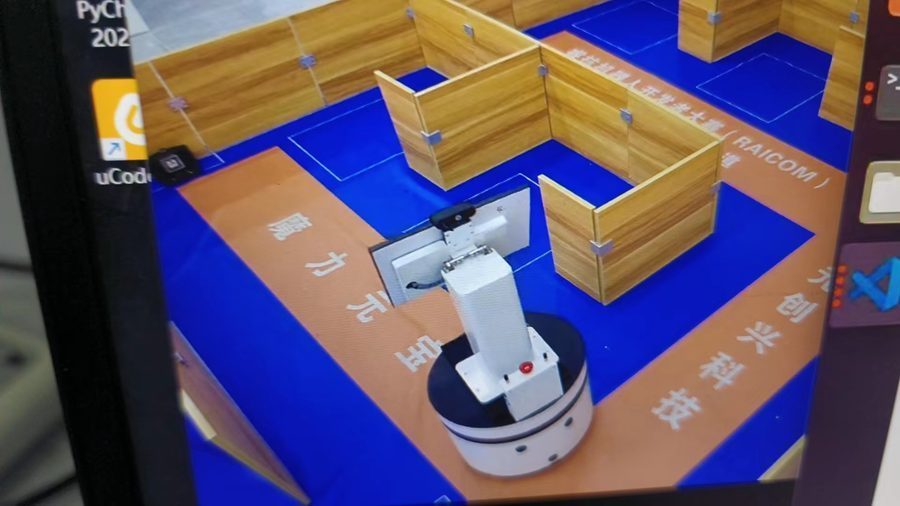
IoT-based Intelligent Building Inspection Robot
A six-wheel inspection robot integrating ROS, SLAM and computer vision for autonomous smart-building security and defect detection.
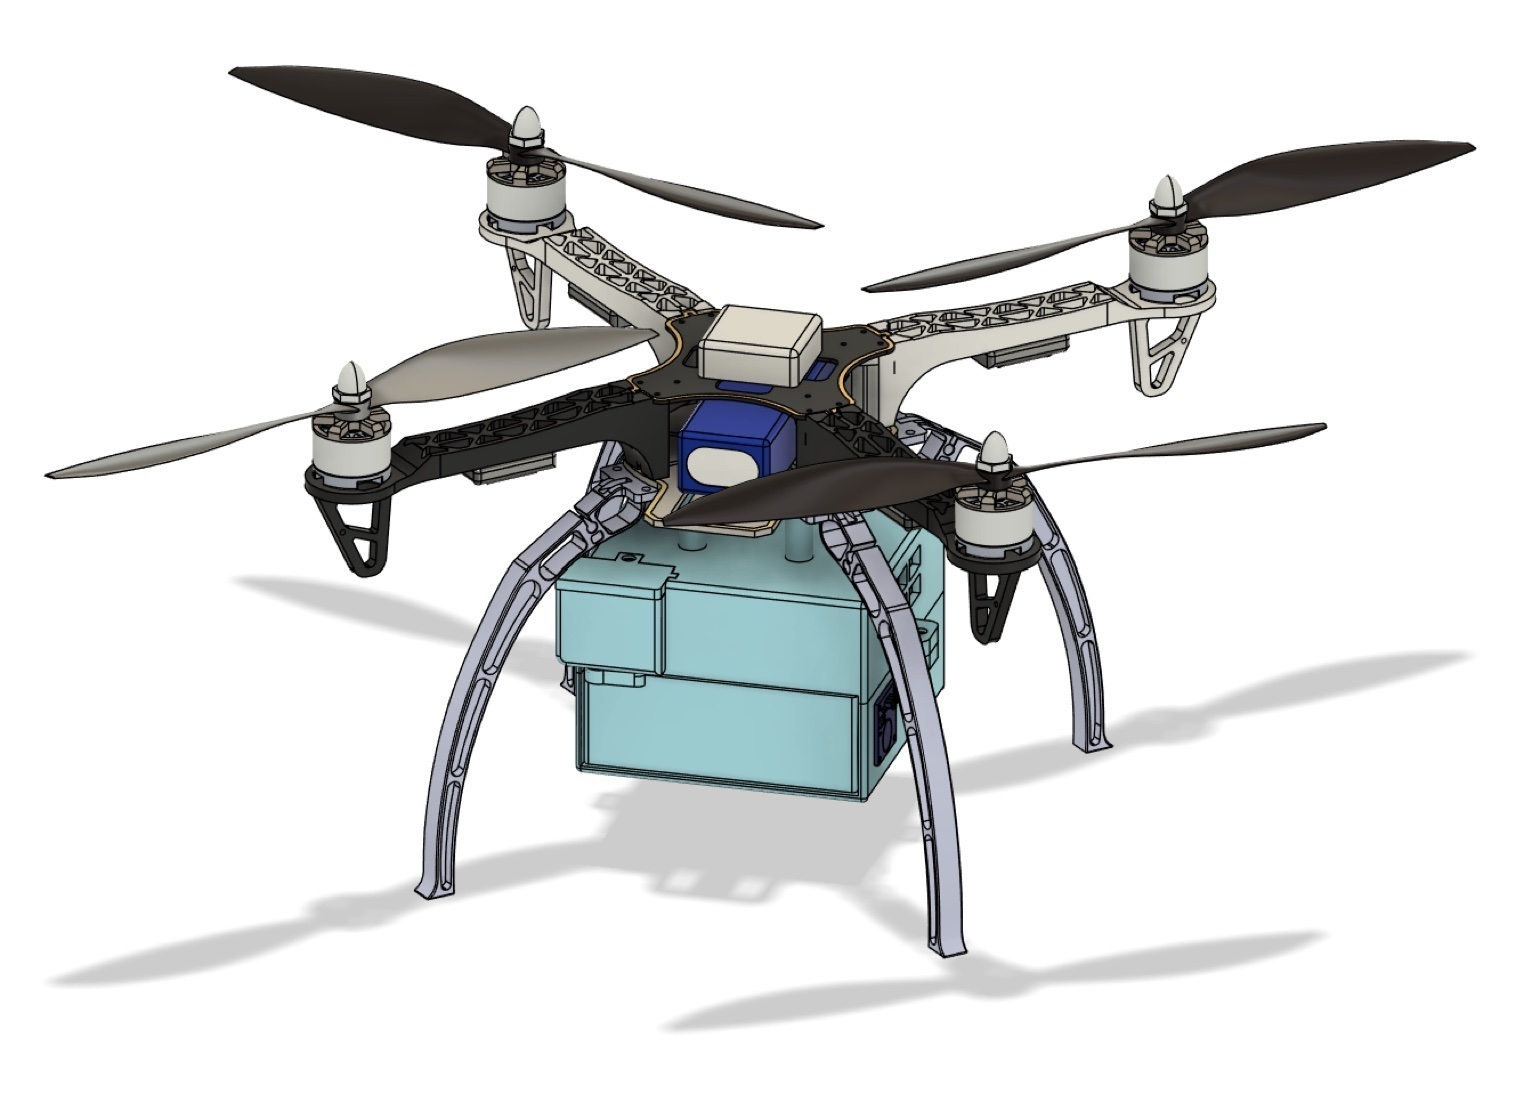
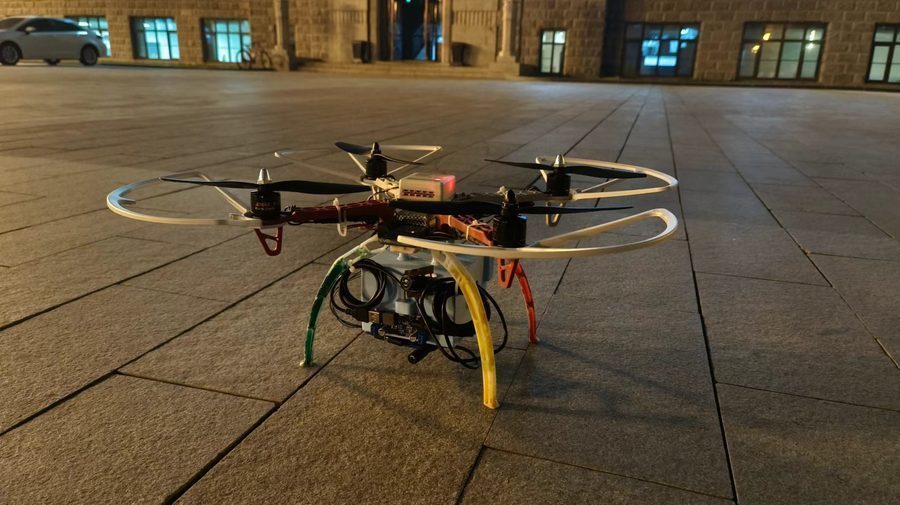
IoT-based Emergency Medicine Delivery Drone System
A drone and IoT system for precise medication delivery, real-time monitoring and remote management in emergencies and remote areas.
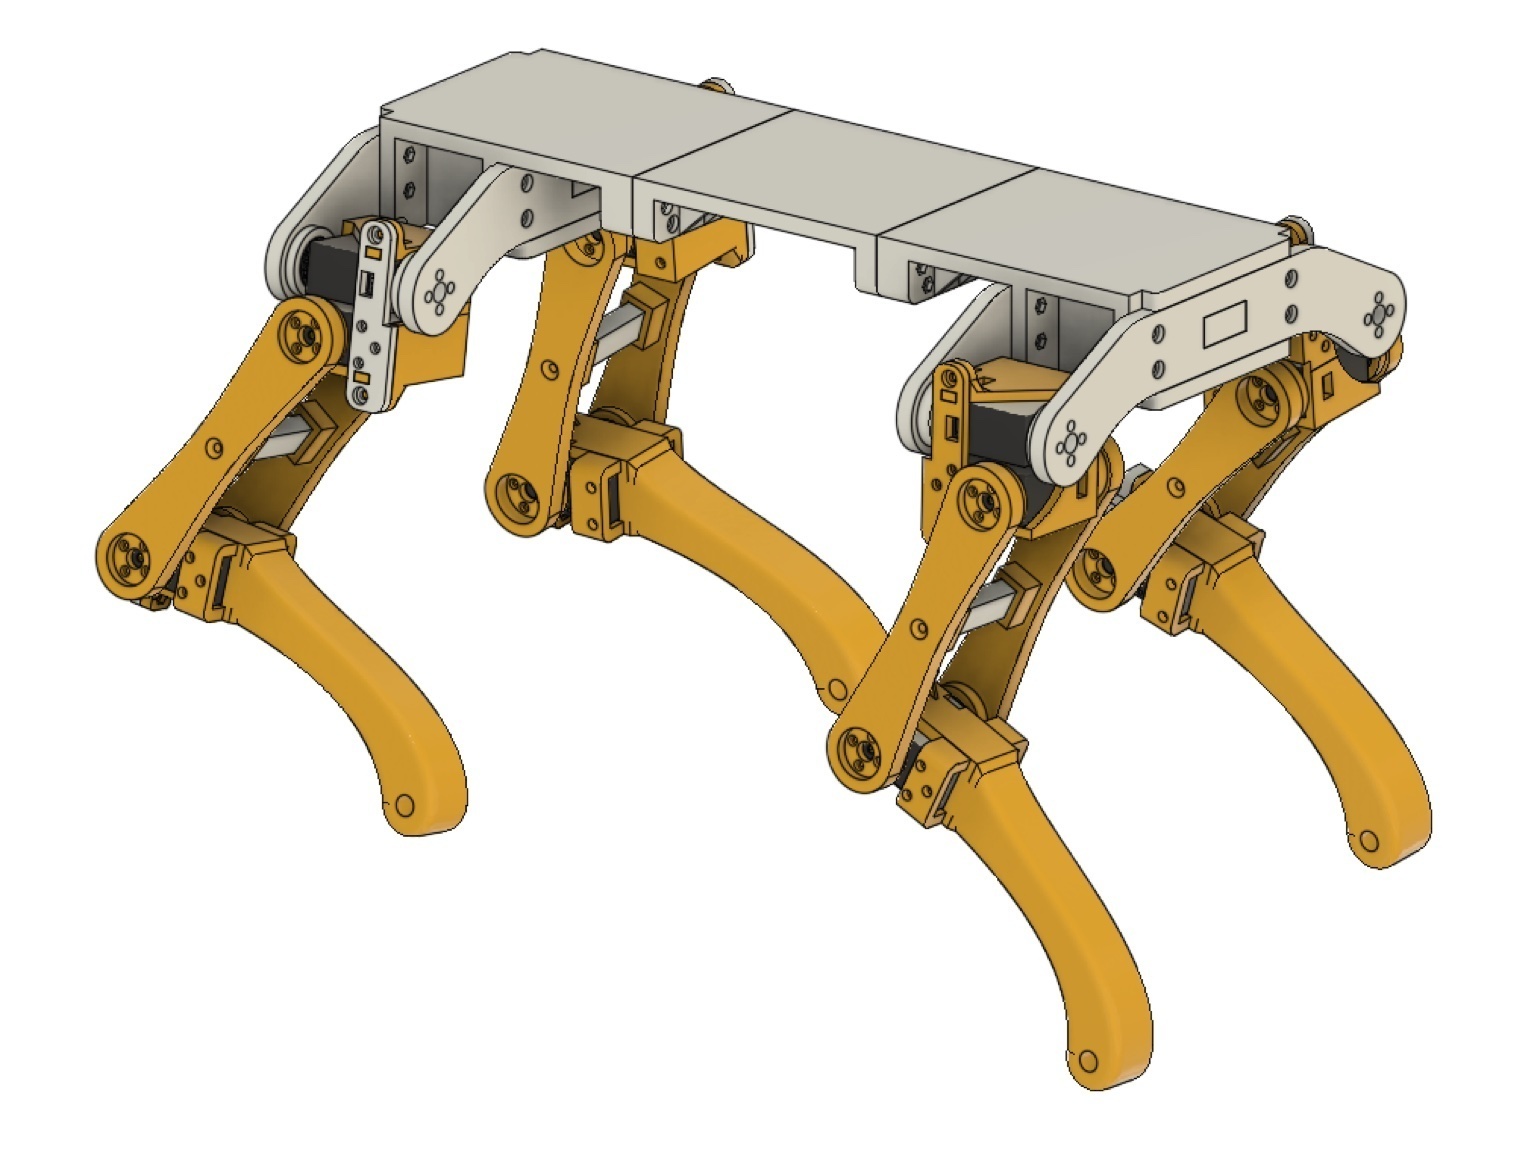
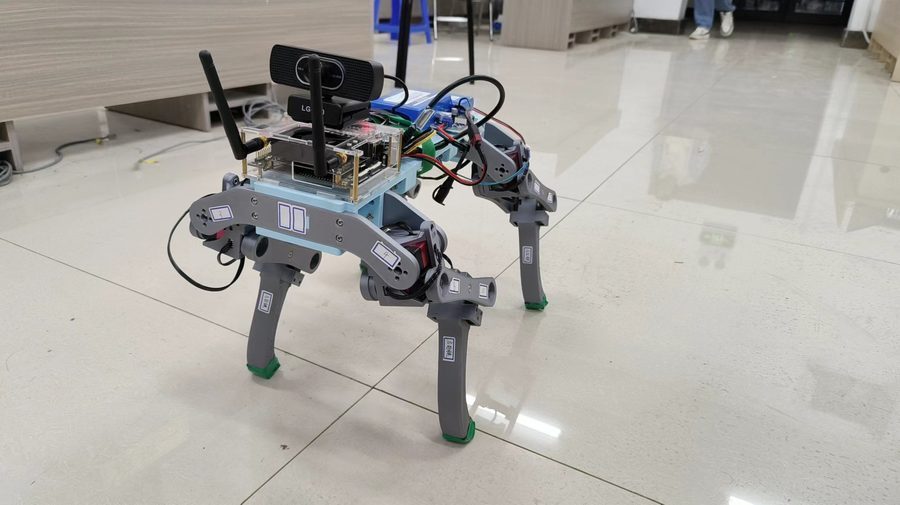
ROS-based Industrial Quadruped Inspection Robot
A 12-DOF quadruped robot with ROS-based SLAM, autonomous navigation, and CPG gait control for efficient and safe industrial inspection.
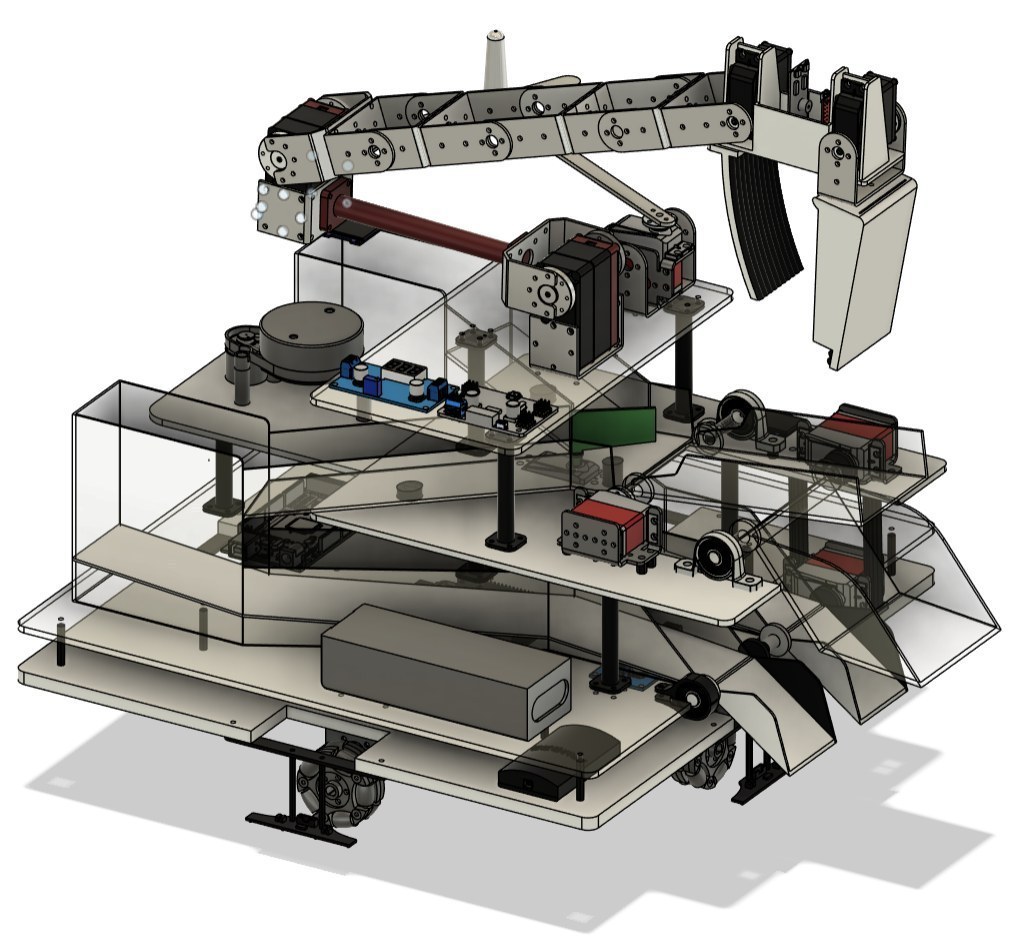
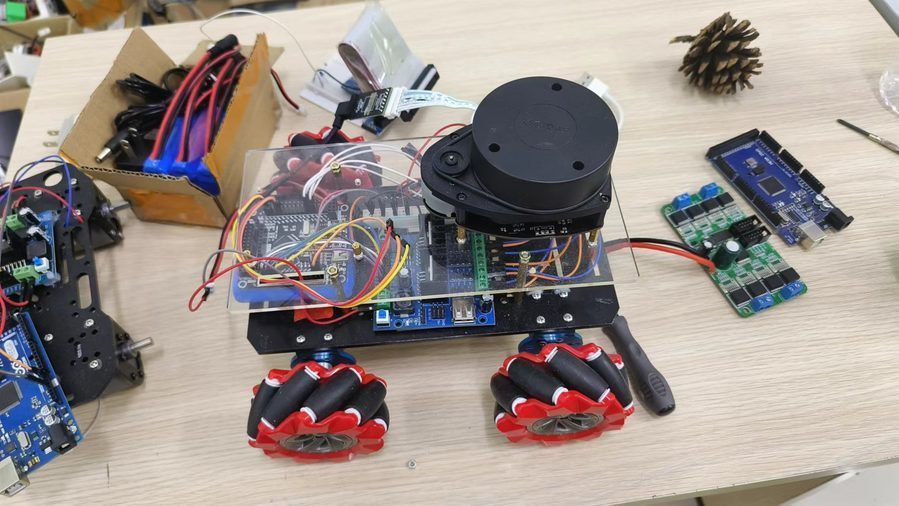
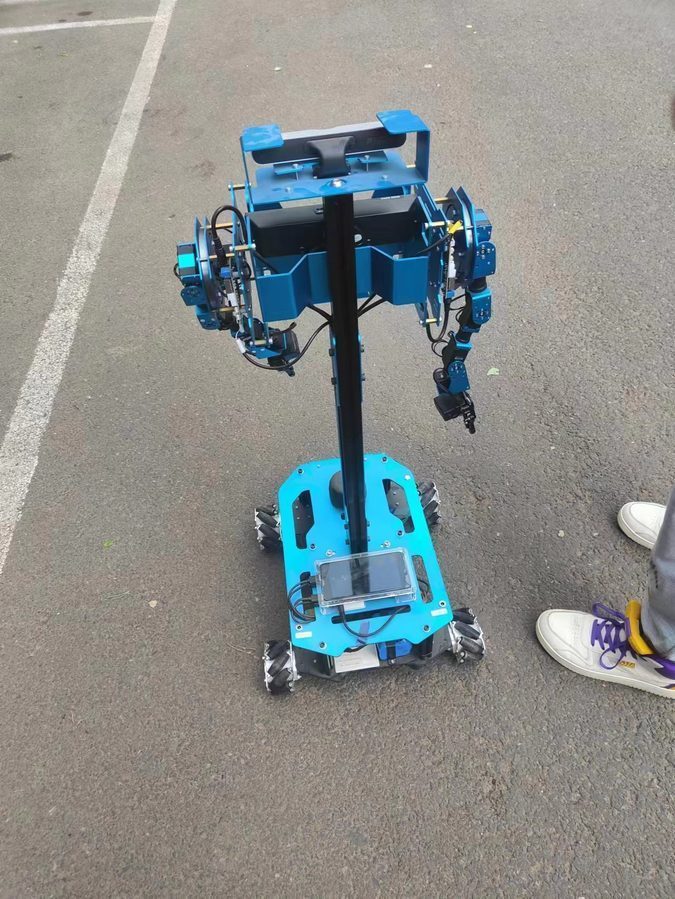
STM32-based Intelligent Logistics Handling Robot
An STM32-based logistics robot with omni-wheel navigation, OpenMV vision and an articulated arm for automated handling, sorting and warehouse storage.
Research Platforms & Equipment
Robotic platforms and systems I have worked with.
ARX Lift2 ARX Dual ARX arms mounted on a vertical lift column, used for bimanual pick-and-place experiments.
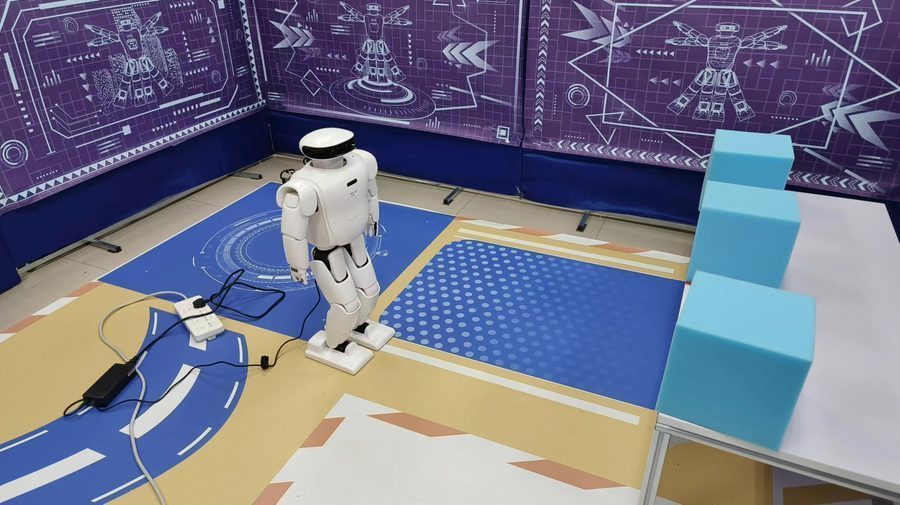
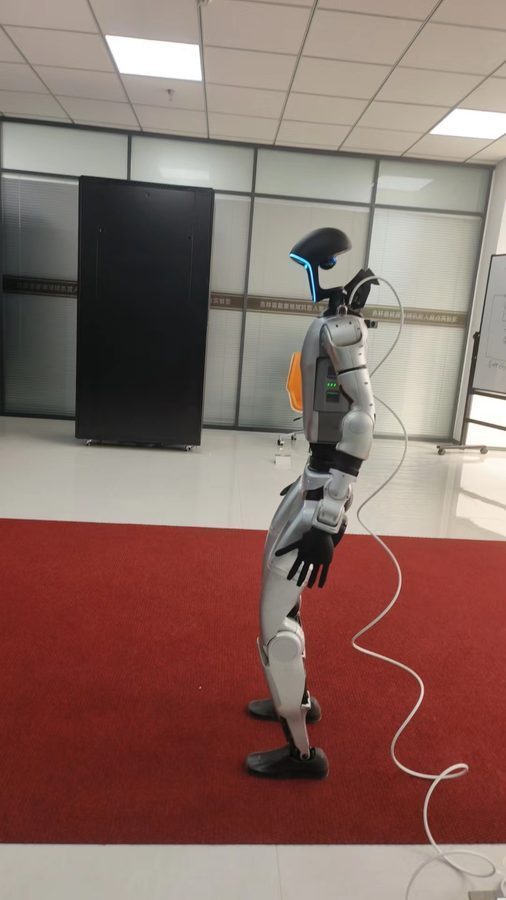
LimX Oli LimX Dynamics Humanoid platform tested on a gantry rig for whole-body motion and teleoperation experiments.
UMI Data-Collection Device with xArm 7 Handheld UMI gripper with RealSense and depth cameras for collecting human demonstration data.
RoboTwin Bimanual Simulation SAPIEN Dual-arm manipulation tasks running in the SAPIEN physics simulator.
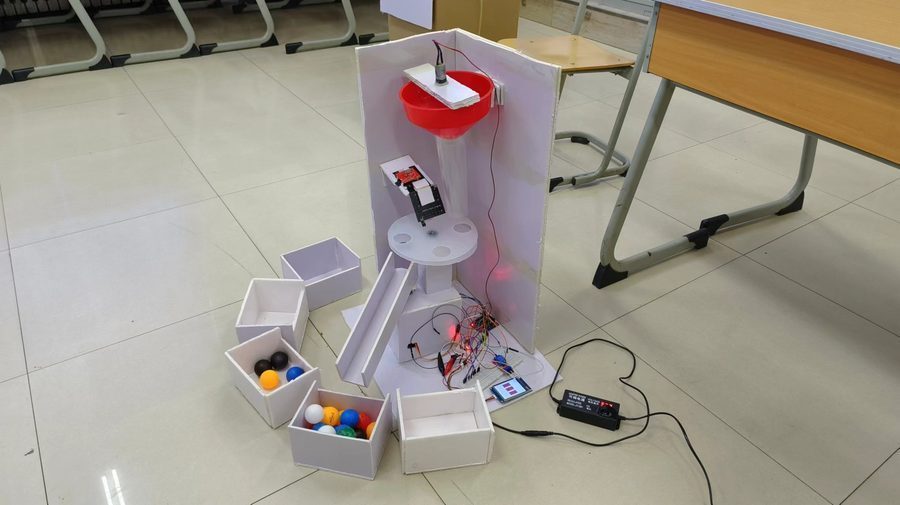
Learning by Building
Small projects from my learning journey.