Robotics · ROS · SLAM
ROS-based Industrial Quadruped Inspection Robot
A 12-DOF quadruped robot system with environment sensing, autonomous decision-making and remote collaboration for efficient and safe industrial inspection.
System Architecture
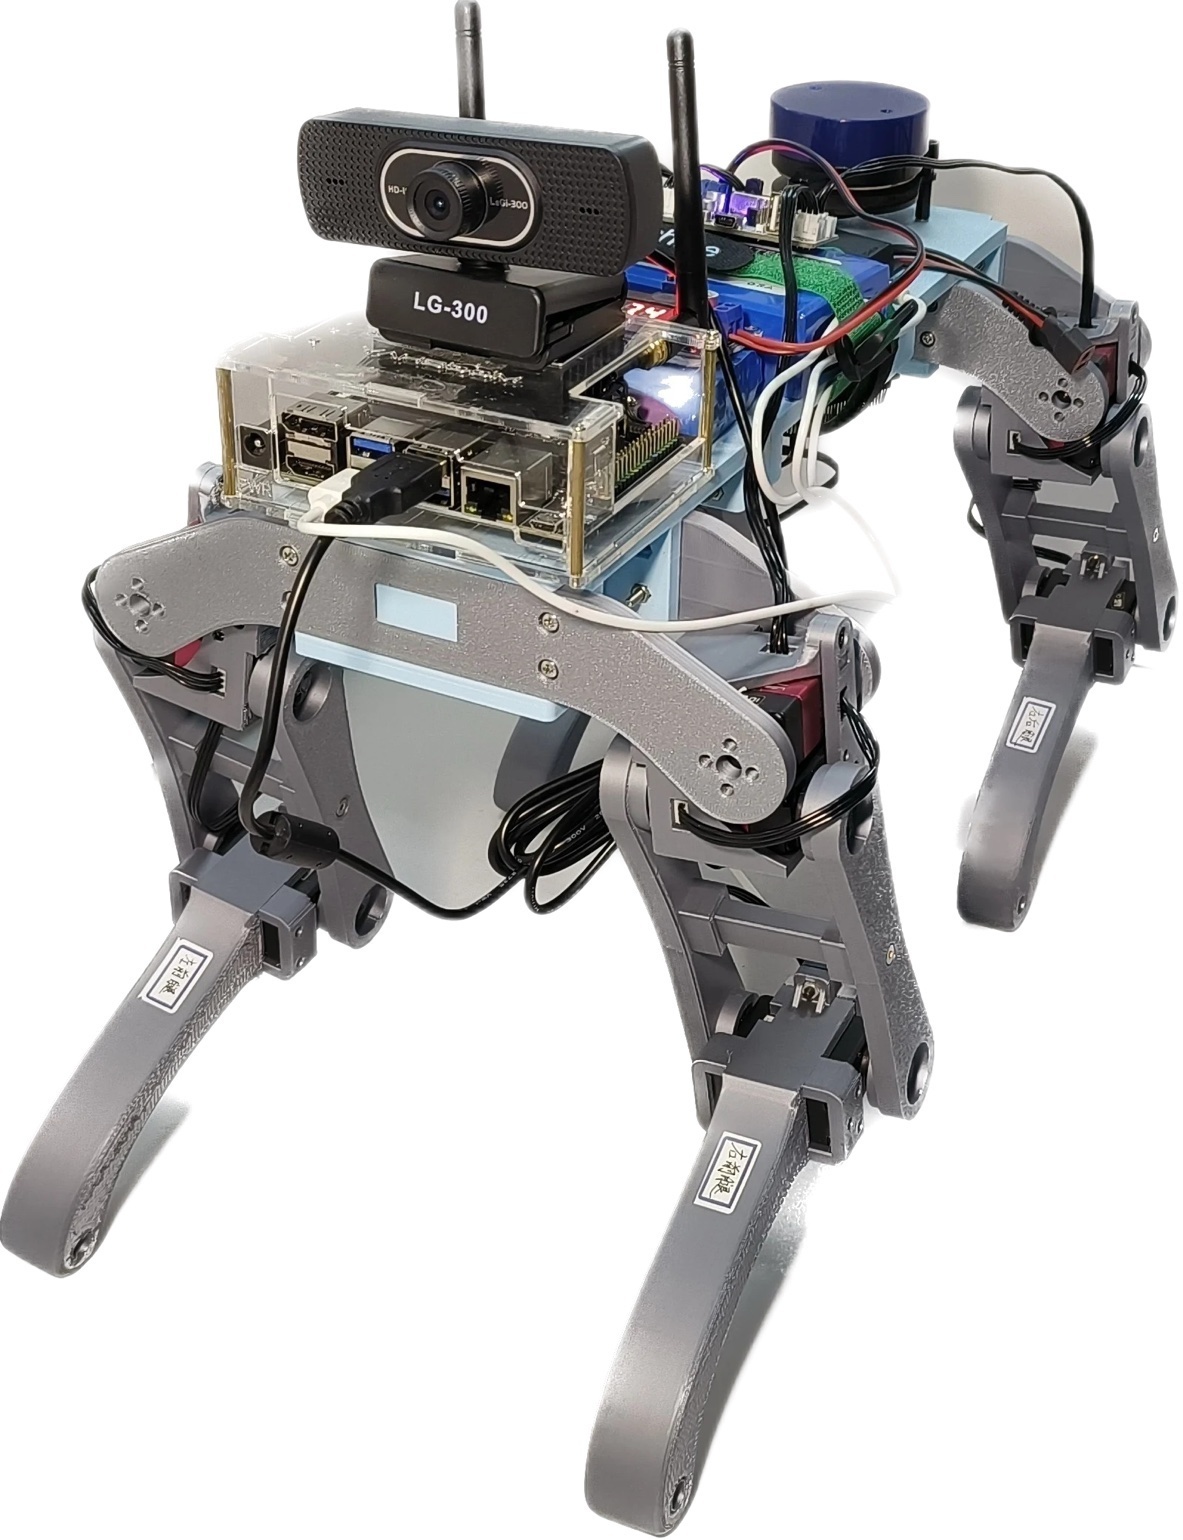
- Sensing actuator layer — LIDAR, IMU, RGB camera and infrared sensors for SLAM and anomaly detection.
- Decision-making layer — ROS-based path planning, obstacle avoidance and task scheduling.
- Human-robot interface — status, maps and video streams over WebSocket.
Mechanical Design
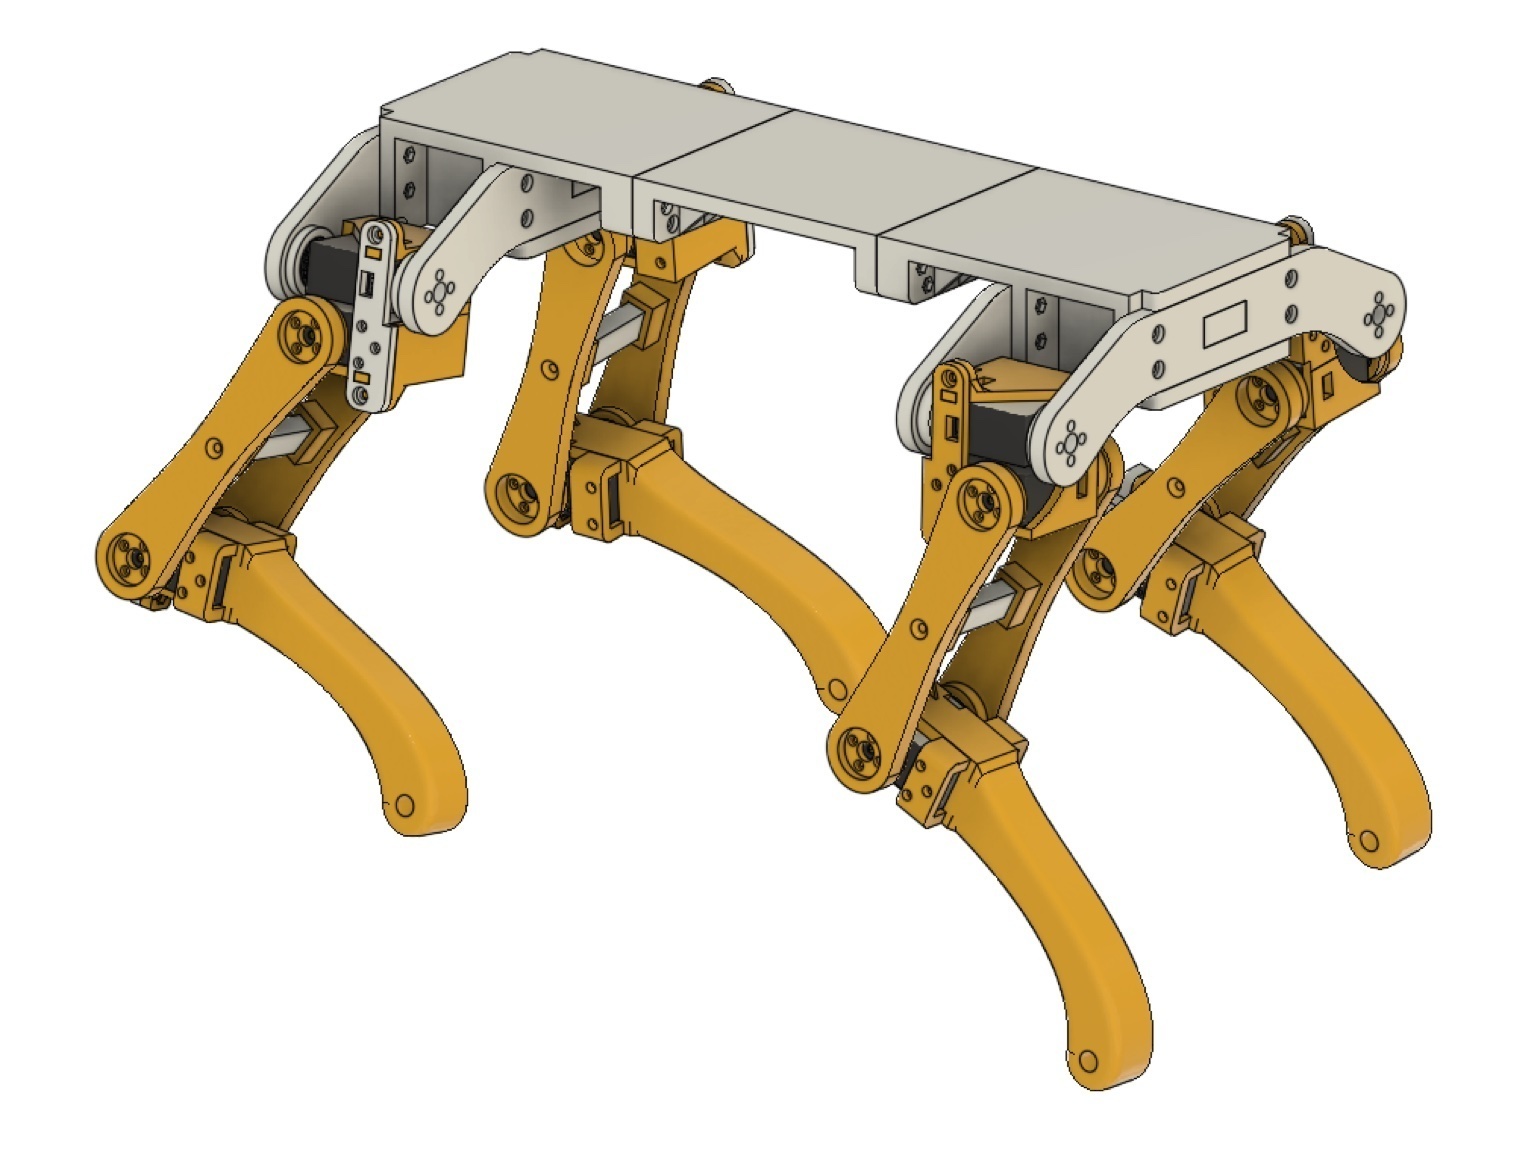
- 12-DOF lightweight design with a hip-knee-ankle configuration.
- 3 high-torque servos per leg for omnidirectional motion control.
- Topology optimization combined with 3D printing.
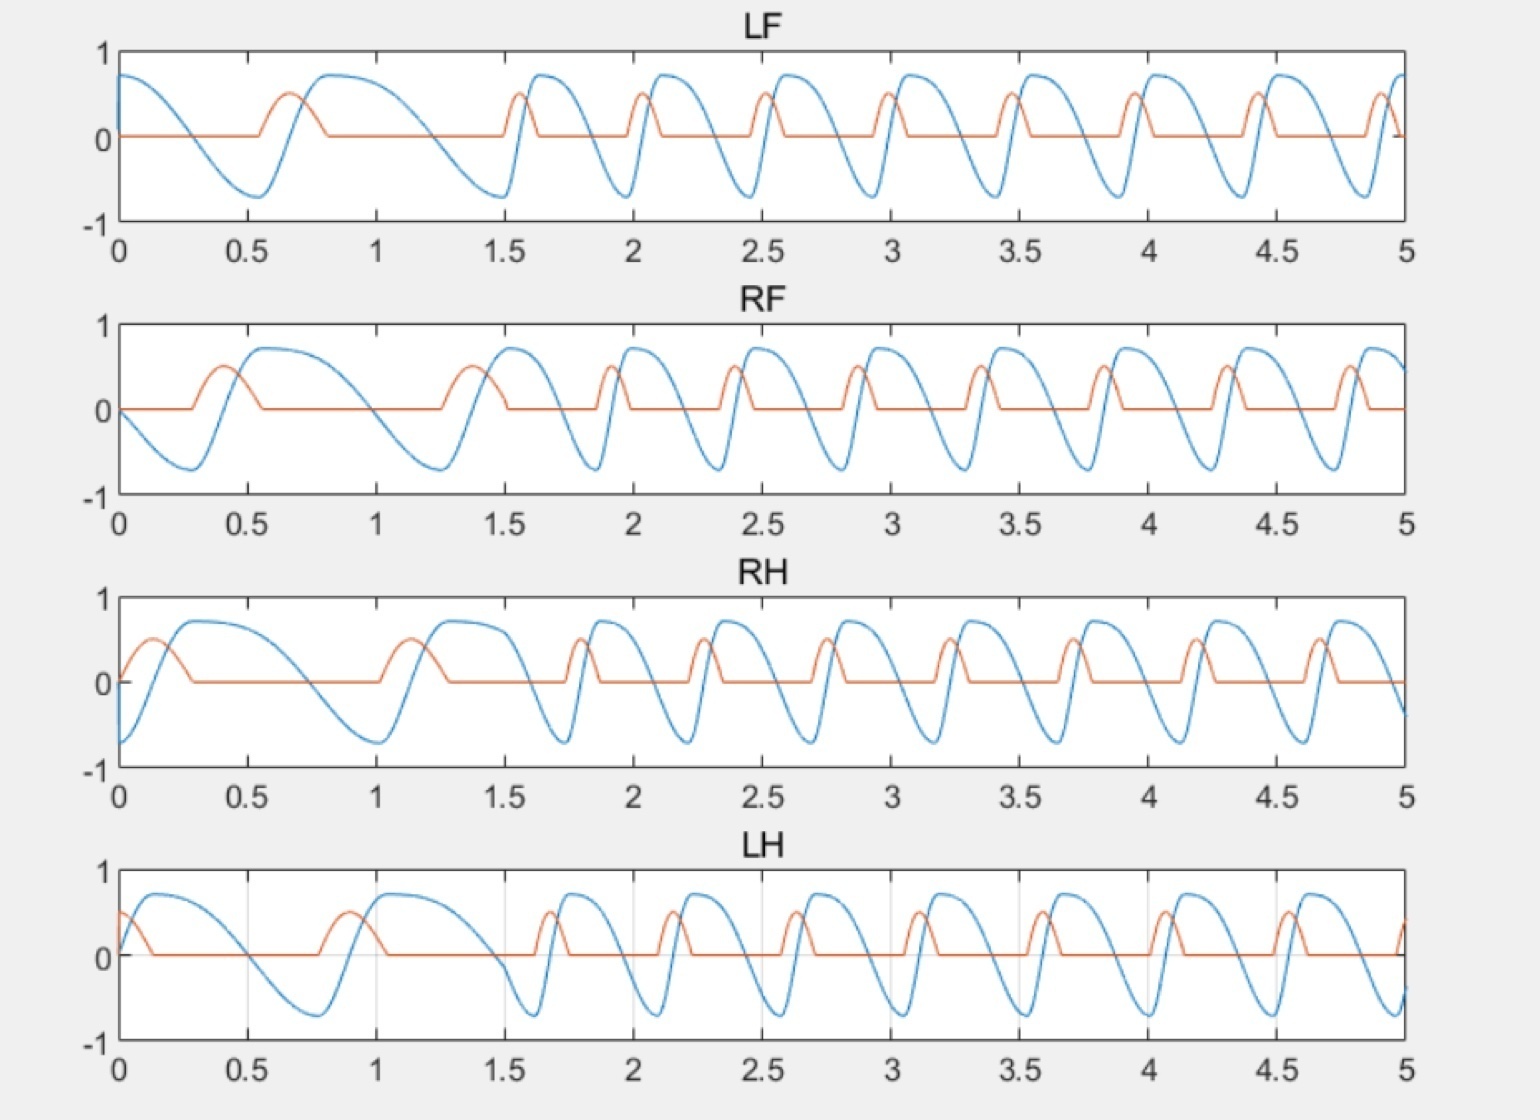
CPG Gait Control
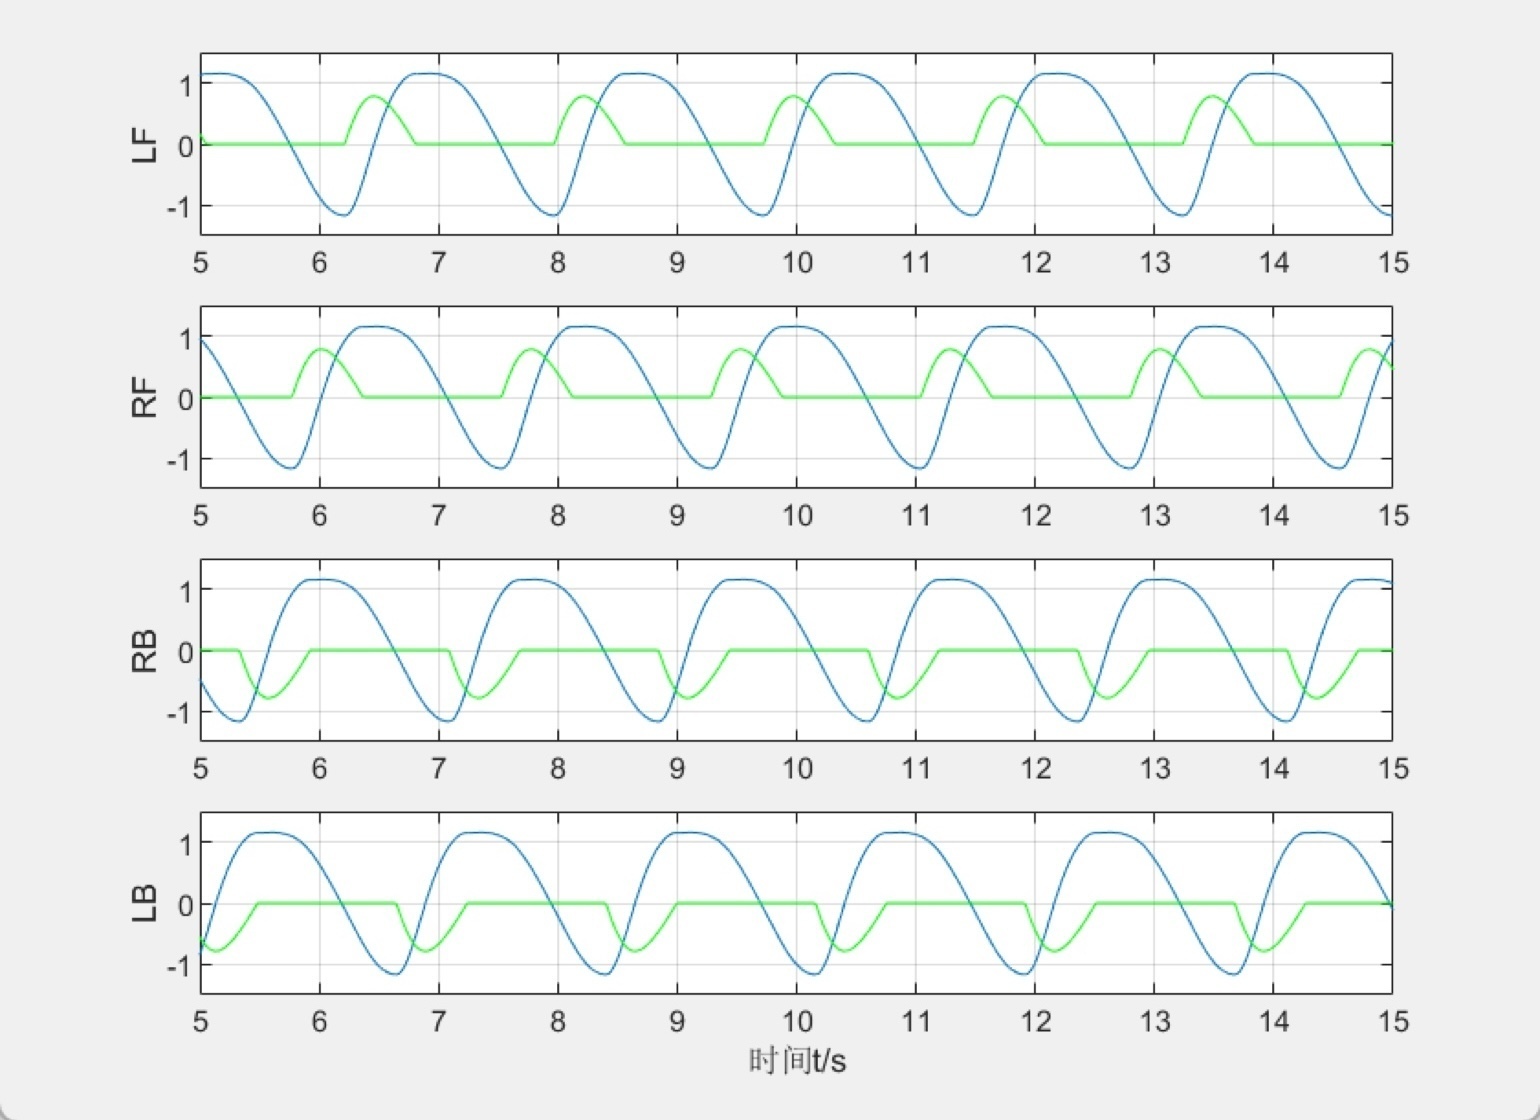
- Distributed CPG network built with Hopf oscillators.
- Ring-coupled topology for coordinated quadruped motion.
- Hip and knee joints use x/y-axis signals for decoupled gaits.
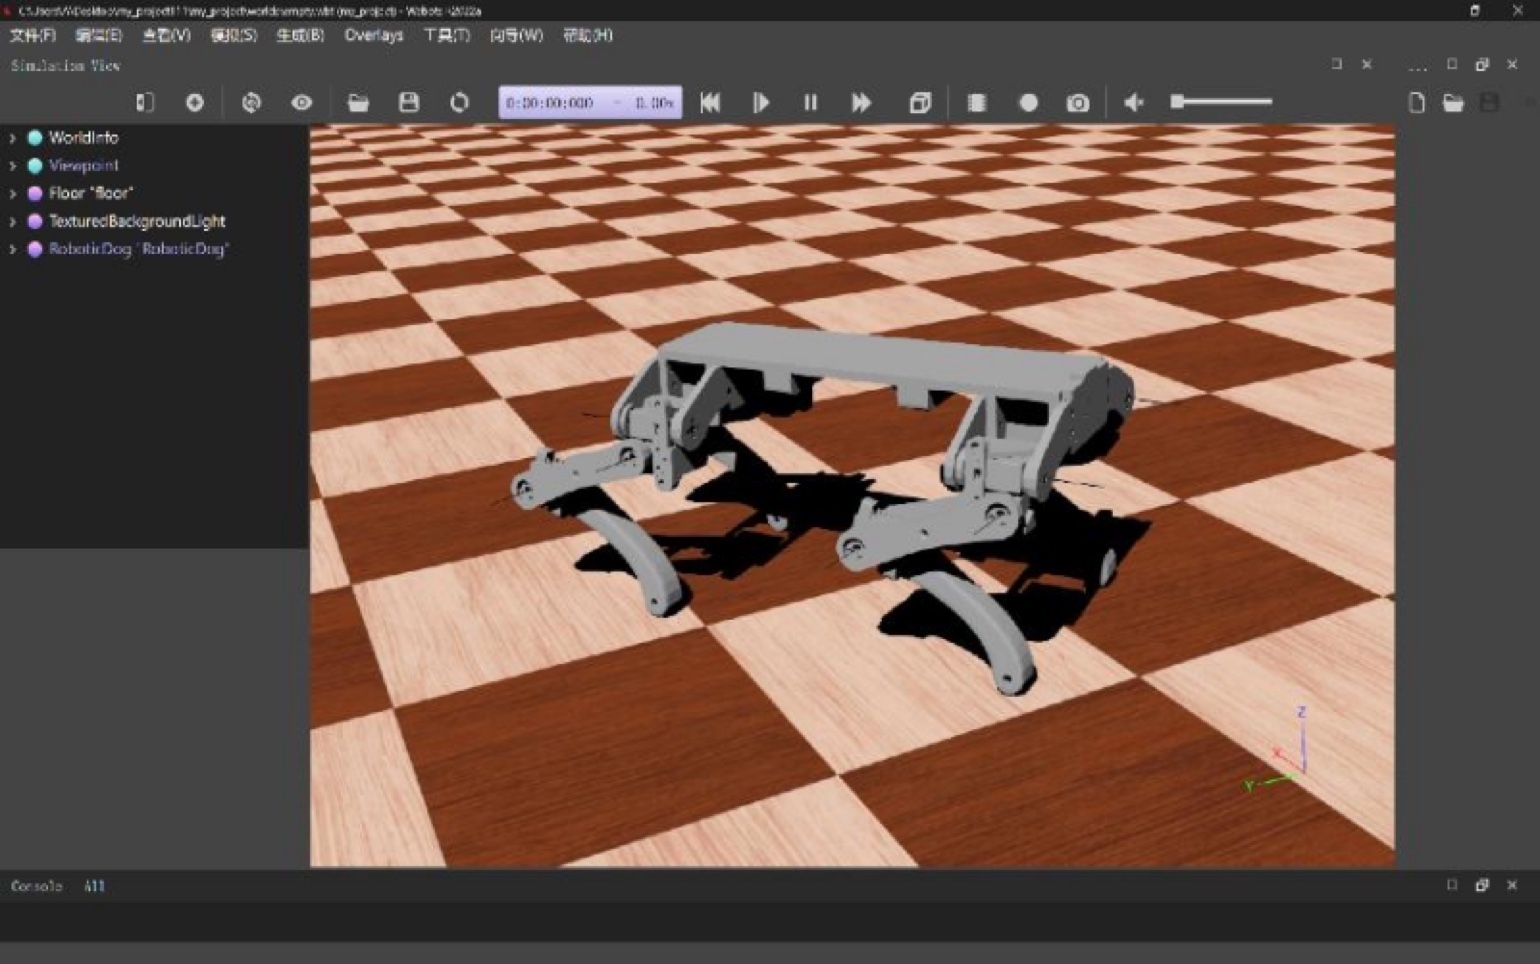
Simulation
- Quadruped dynamics model on Webots.
- Smooth trajectories through kinematics analysis.
- VMC with spring-damping for dynamic force adjustment.