IoT · ROS · SLAM
IoT-based Intelligent Building Inspection Robot
A smart building security system integrating ROS, SLAM and computer vision with a six-wheel design for autonomous inspection, enhancing security automation and intelligence.
System Architecture
- Arduino-Raspberry Pi master-slave control via
ros_arduino_bridge. - PWM motor speed control with a PID closed-loop algorithm.
- ROS distributed computing offloads high-load tasks to the center.
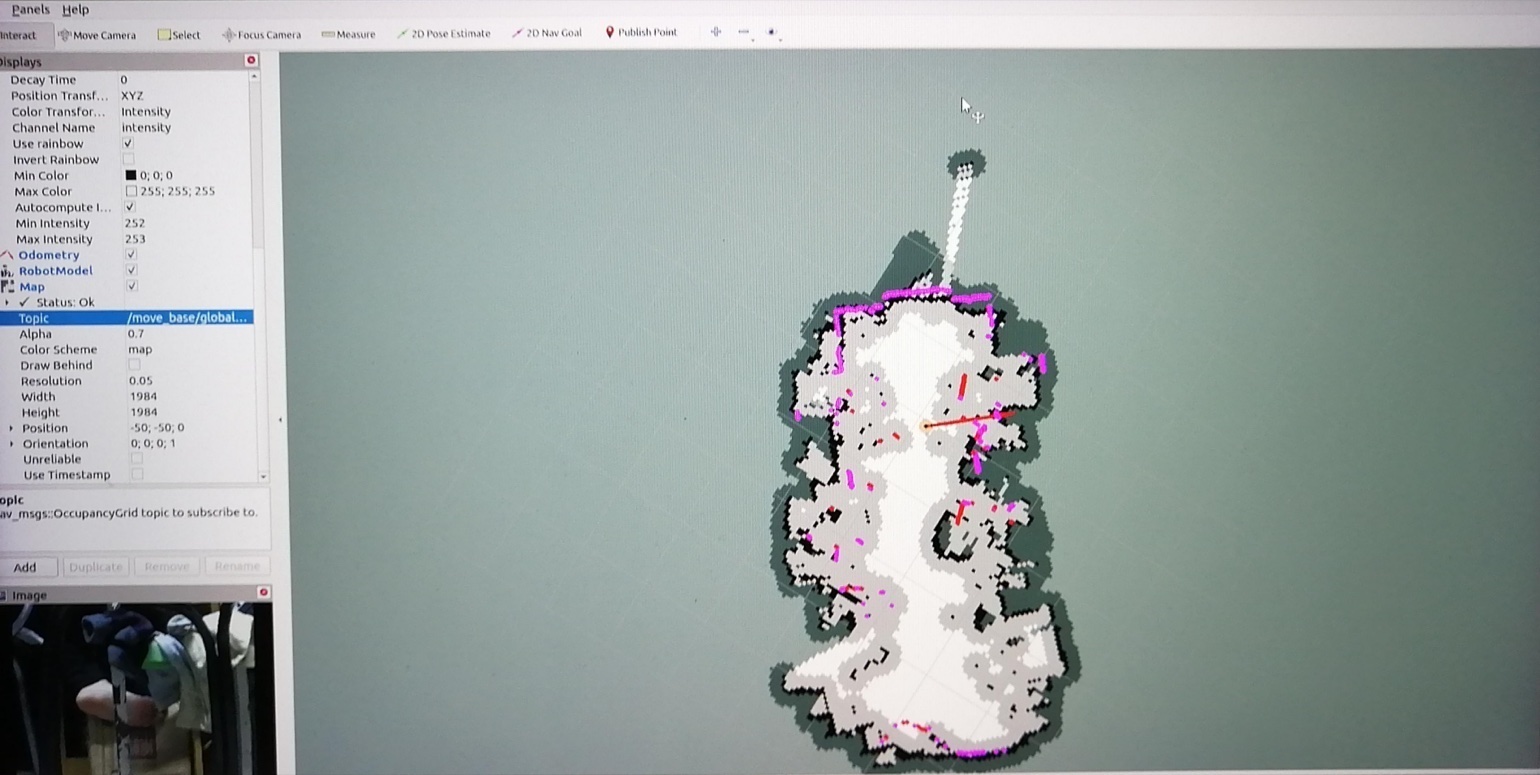
Perception and Navigation
- Navigation: Cartographer SLAM and autonomous path planning.
- Vision: YOLOv7-based defect detection.
Monitoring Dashboard
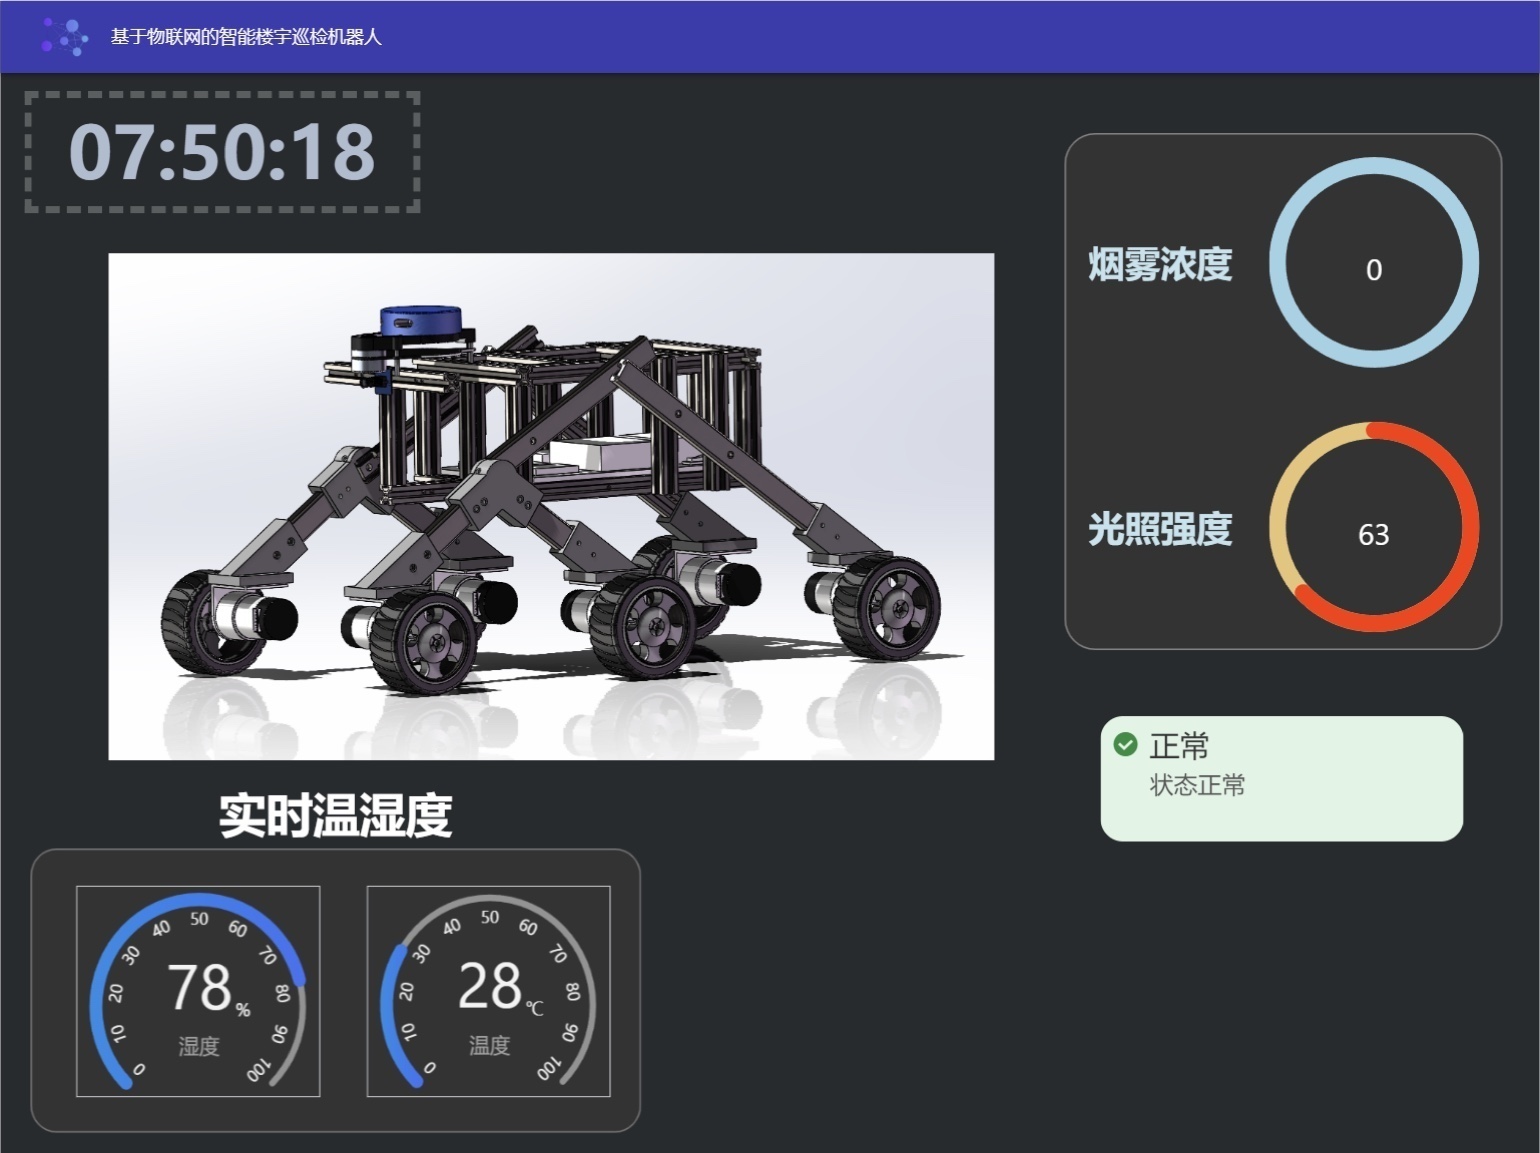
- Real-time temperature, humidity, smoke and light monitoring.
- Reports the robot's operating status to the center.
Mechanical Design
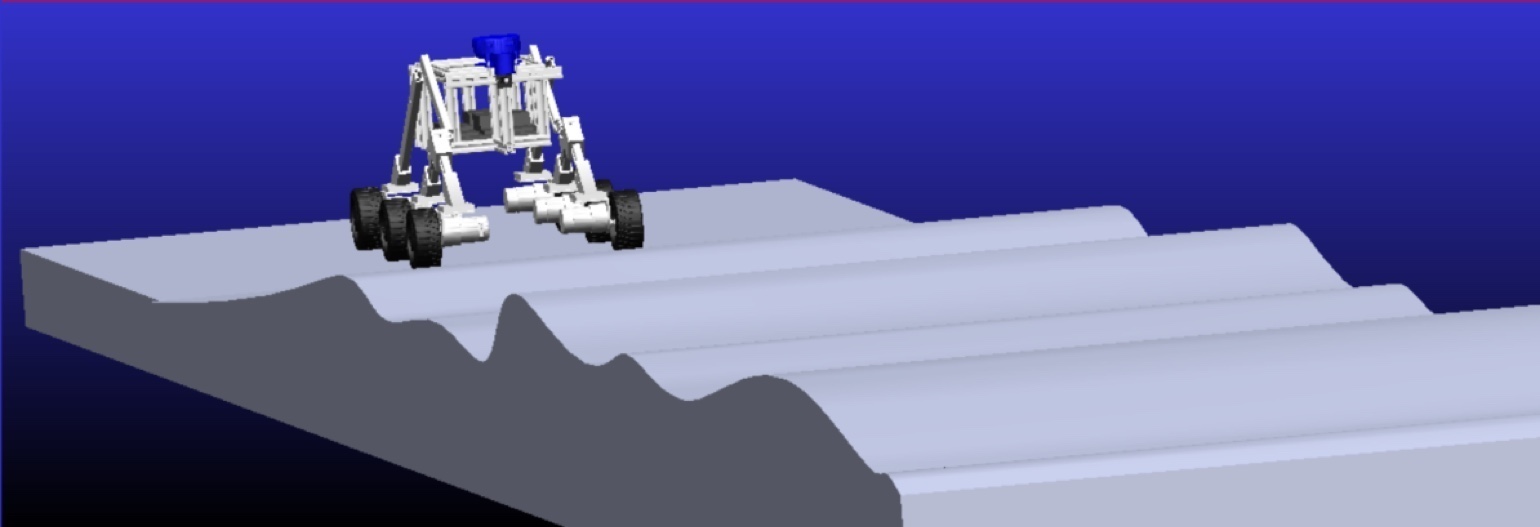
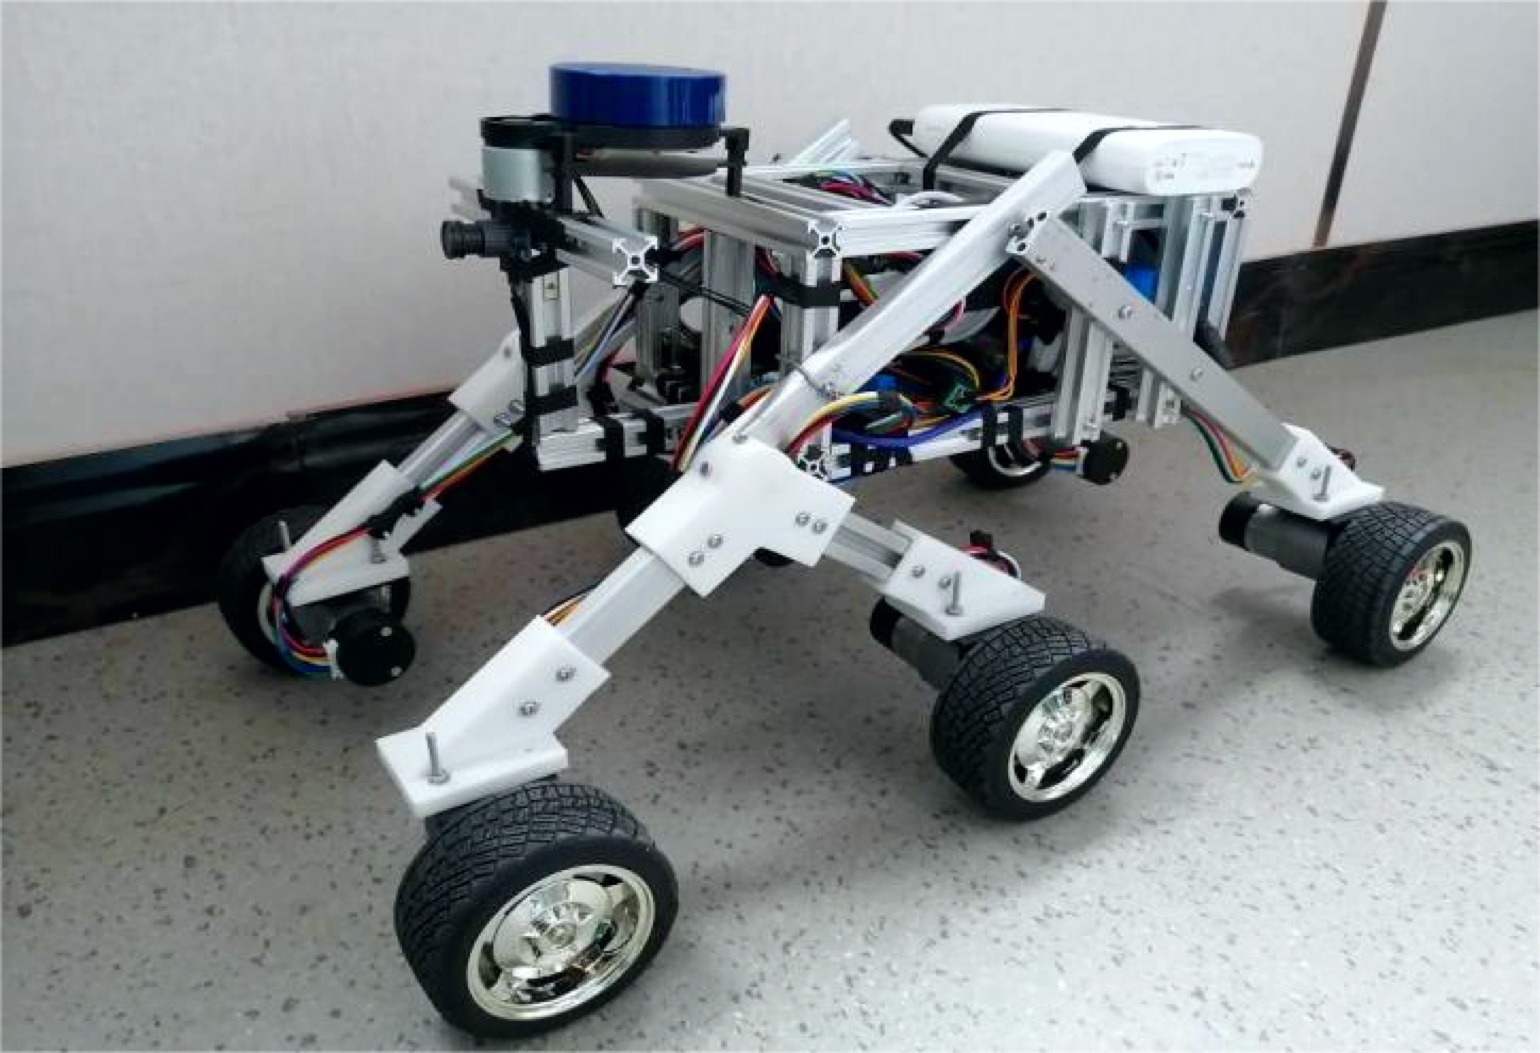
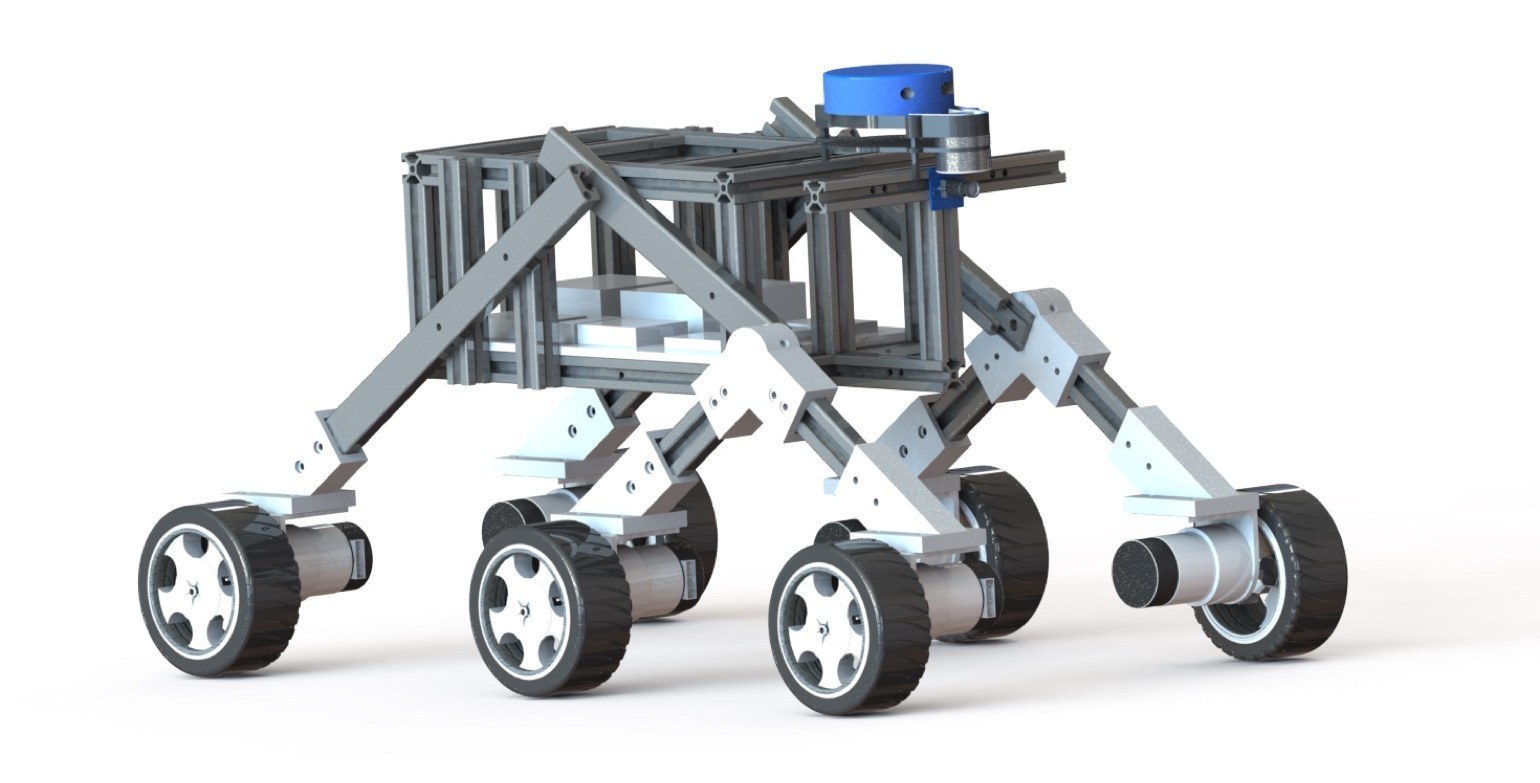
- Six-wheel rocker-arm suspension for stable mobility on uneven terrain.
- Protects sensitive components with optimal ground clearance.
Performance Analysis
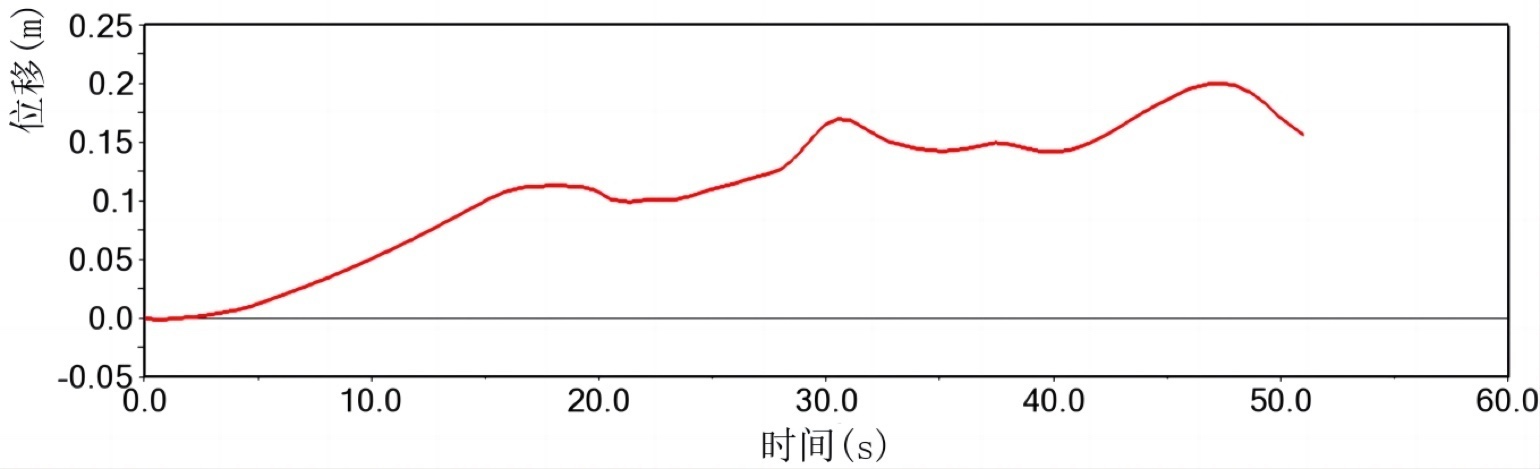
- Y-axis center-of-gravity displacement varies linearly with slope.
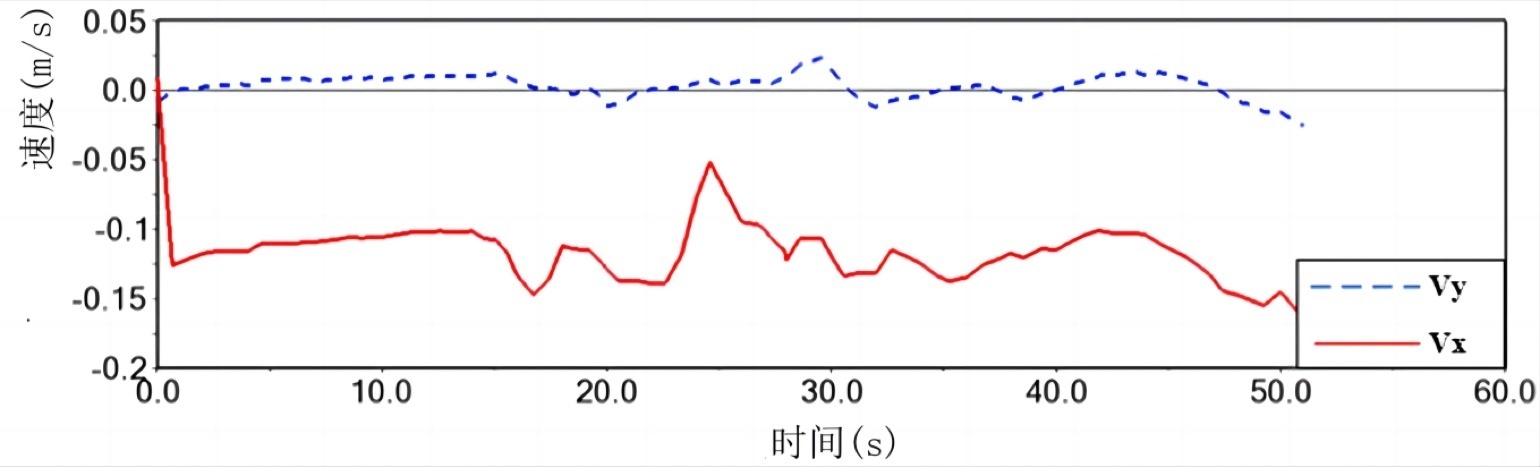
- X/Y-axis velocity components adjust dynamically with slope changes.