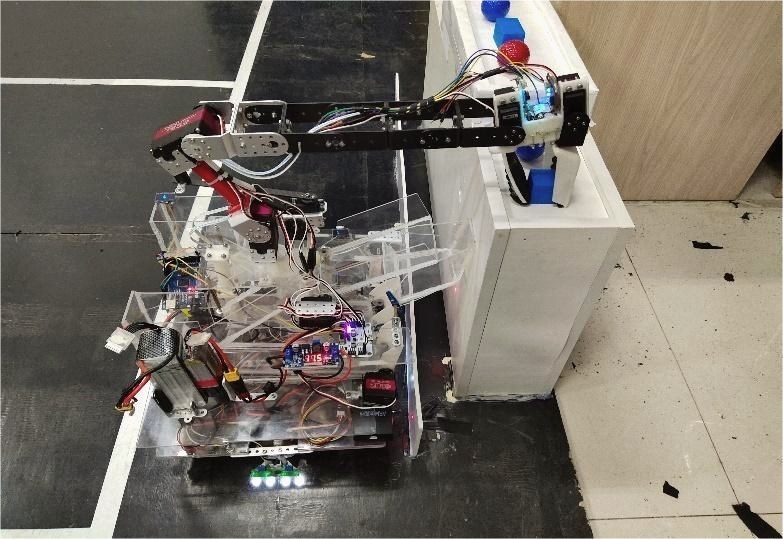
Embedded · STM32 · Robotics
STM32-based Intelligent Logistics Handling Robot
Rapid e-commerce growth highlights the limits of manual sorting. This project develops an STM32-based intelligent logistics robot for efficient, automated handling and sorting, improving logistics efficiency and reducing costs.
System Architecture
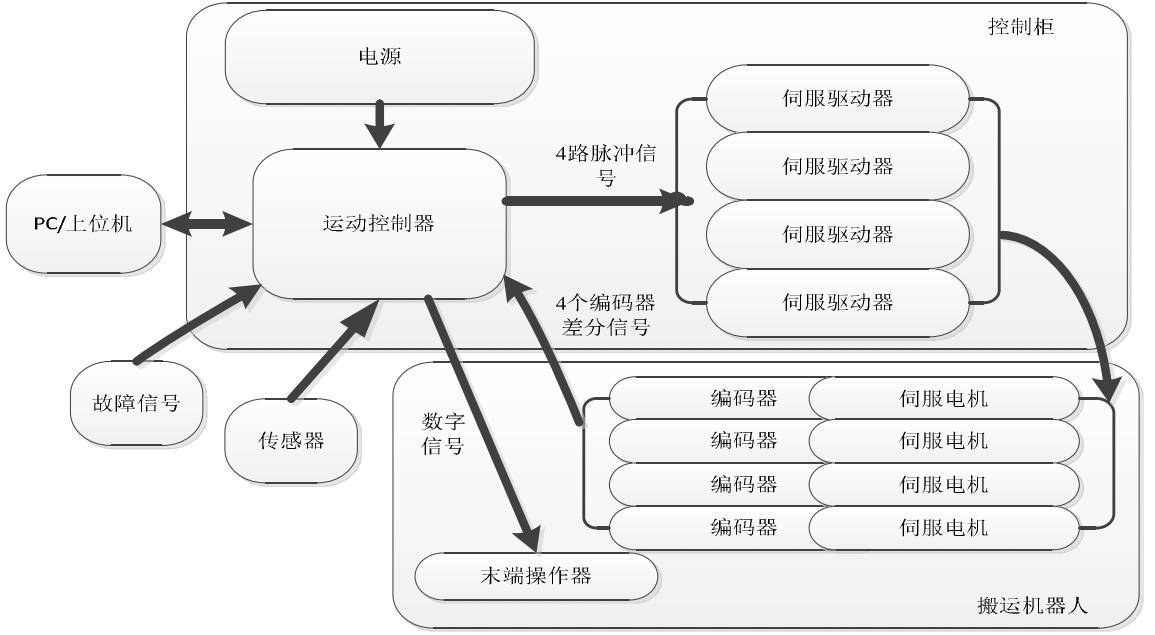
- Control core — STM32 manages the system, with serial links to Arduino and OpenMV.
- Movement — omni-wheels guided by grayscale and laser sensors with PID control.
- Functions — object recognition via OpenMV, grasping by the robotic arm, item classification and storage, and ultrasonic obstacle avoidance.
- Communication — serial links connect all modules.
Mechanical Design
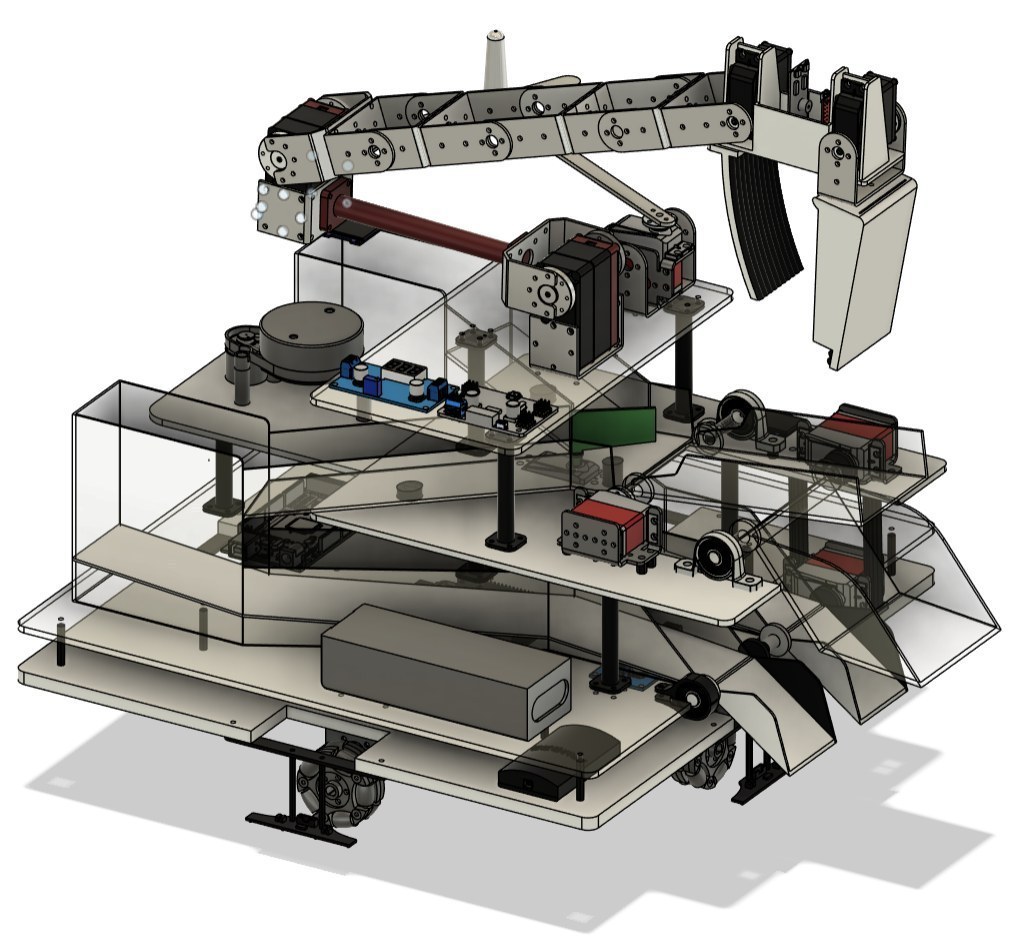
- Multi-layer acrylic chassis housing the control cabinet and drives.
- Articulated robotic arm for grasping and placing items.
- Four omni-directional wheels for holonomic movement.
- Fabrication — modeled in Fusion360/CATIA and built with 3D printing and acrylic.
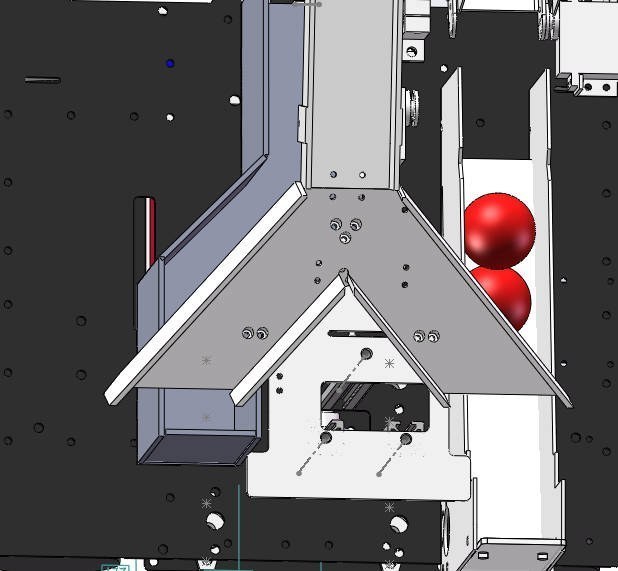
Storage and Sorting Warehouse
- Double-layer design — the upper layer handles distribution, the middle layer stores items.
- Classified storage — subdivided areas for various shapes, ensuring accurate placement.
- Item process — items enter via a guiding channel, are sorted by the distribution piece, then stored.
Prototype
- Integrated STM32 control cabinet with servo drivers and encoders.
- OpenMV vision for object recognition and classification.
- Ultrasonic sensors for obstacle avoidance during handling.